
3D Hangar · Current R2 package · 31 October 2026
Zephyr 900 build guide
Interactive 3D viewerFree · name and email required
Print and fit prototype: physical printing, installed hardware and flight validation remain outstanding.
What changed
- Rebuilt chassis and servo coupon with full-depth compression posts and accessible through-bolt retention.
- Reserved the battery manufacturer’s maximum 61 × 33 × 13 mm case and moved 8 mm strap slots to X110/X145.
- Raised HS-40 reference cases to the actual ear plane and rebuilt affected plates.
These are digital design and documentation checks. No new physical print, load, radio, water or flight tests have been performed.
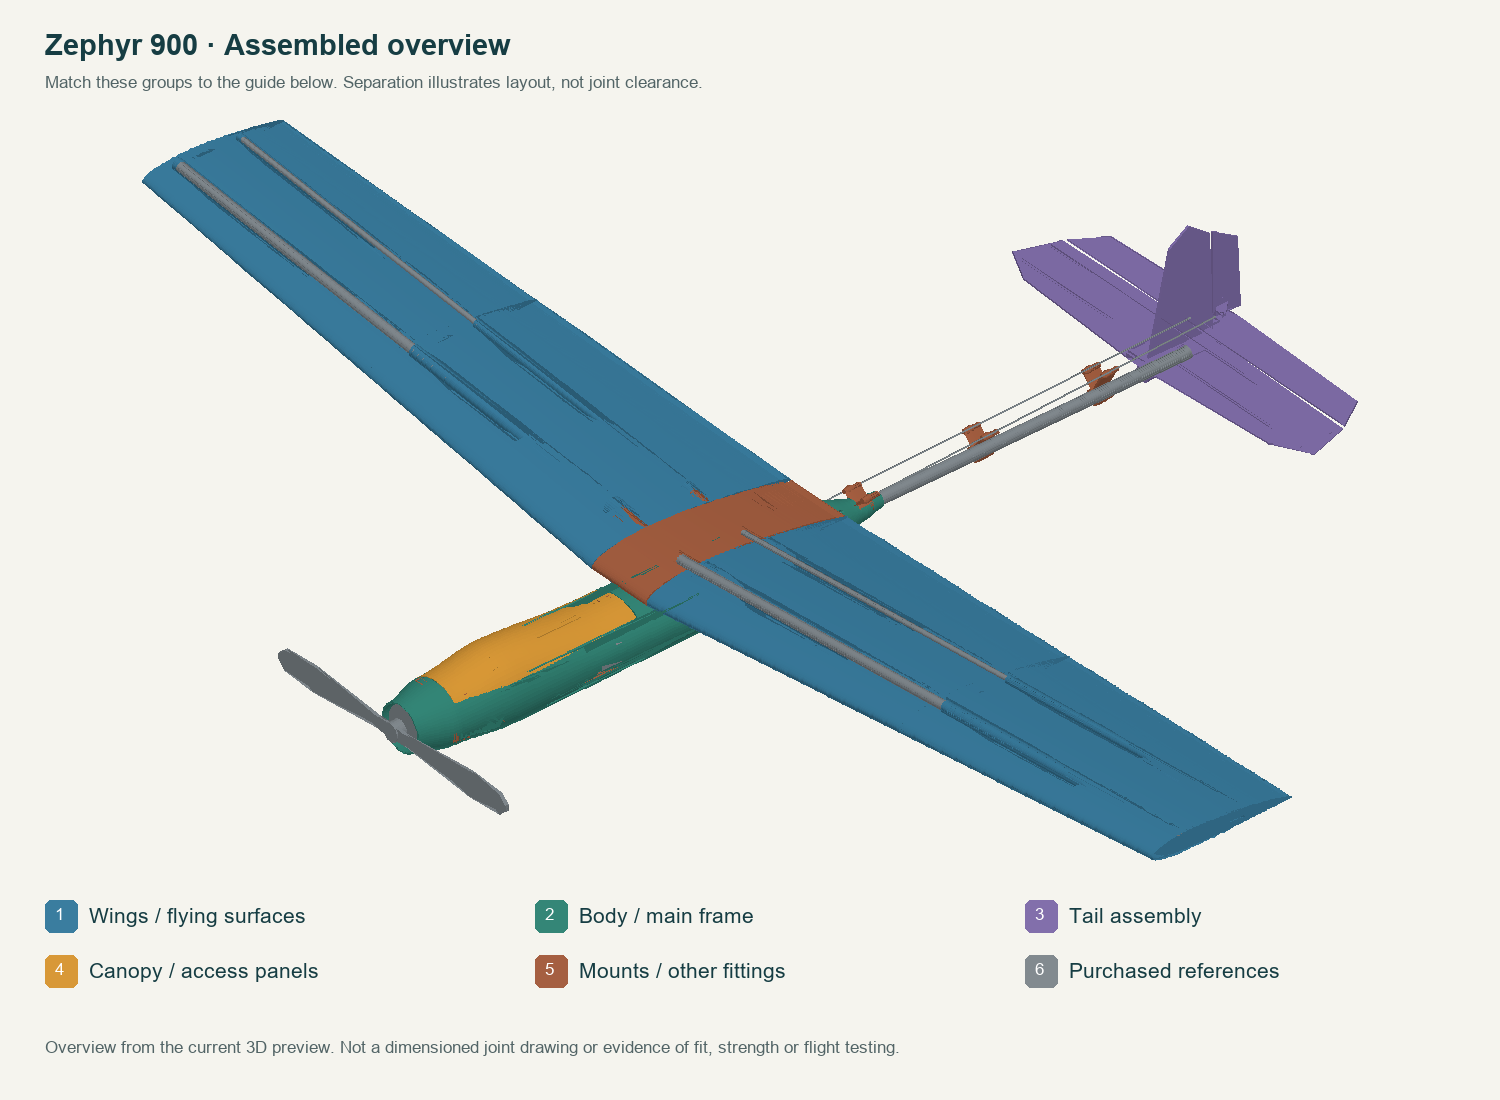
Before printing
Use the supplied orientation and 100% scale. The 3MF files contain geometry and arrangement, not a validated printer/material profile or ready-to-run G-code. Use the material listed for each plate. Slice with supports off where specified and inspect the first layers, bridges, thin-wall continuity and holes before printing.
Mounting and connection details
Coordinates refer to the assembled CAD datum, not the slicer’s rearranged plate. Dimensions below are millimetres unless stated otherwise.
| Interface | Dimension / part | Assembly action |
|---|---|---|
| HS-40 mounts | Four Ø2.3 mm holes at X237.2/260.8, Y±10; ear support Z26. | Use four M2 through-bolts with washers and nuts below the chassis floor. Start with 22–25 mm lengths and select from the measured stack; do not put nuts beside the servo cases. |
| Battery | Gens ace 450 mAh 2S: reserve 61 × 33 × 13 mm at X97–158, Y±16.5, Z12–25. | Two 8 mm straps at X110/X145; lead/connector space forward at X80–97. Close the canopy with all wires restrained. |
| Motor | Original SunnySky X2204-1480 has integral ears and supplied mounting screws. | Transfer the real ear pattern onto the provided motor fit land, then the firewall. No invented M3 blind-thread pattern or penetration depth. |
| Carbon | Two 6/4 mm main spars and two 3/2 mm rear spars, each 446.62 mm; 8/6 mm boom, 328 mm. | OD/ID notation. Trial the actual stock before cutting all members; preserve continuous pieces. |
| Canopy | Four 6 × 2 mm axial discs in two attracting pairs. | Set polarity before bonding caps. Front up about 5°, move 12 mm toward the nose, then lift. |
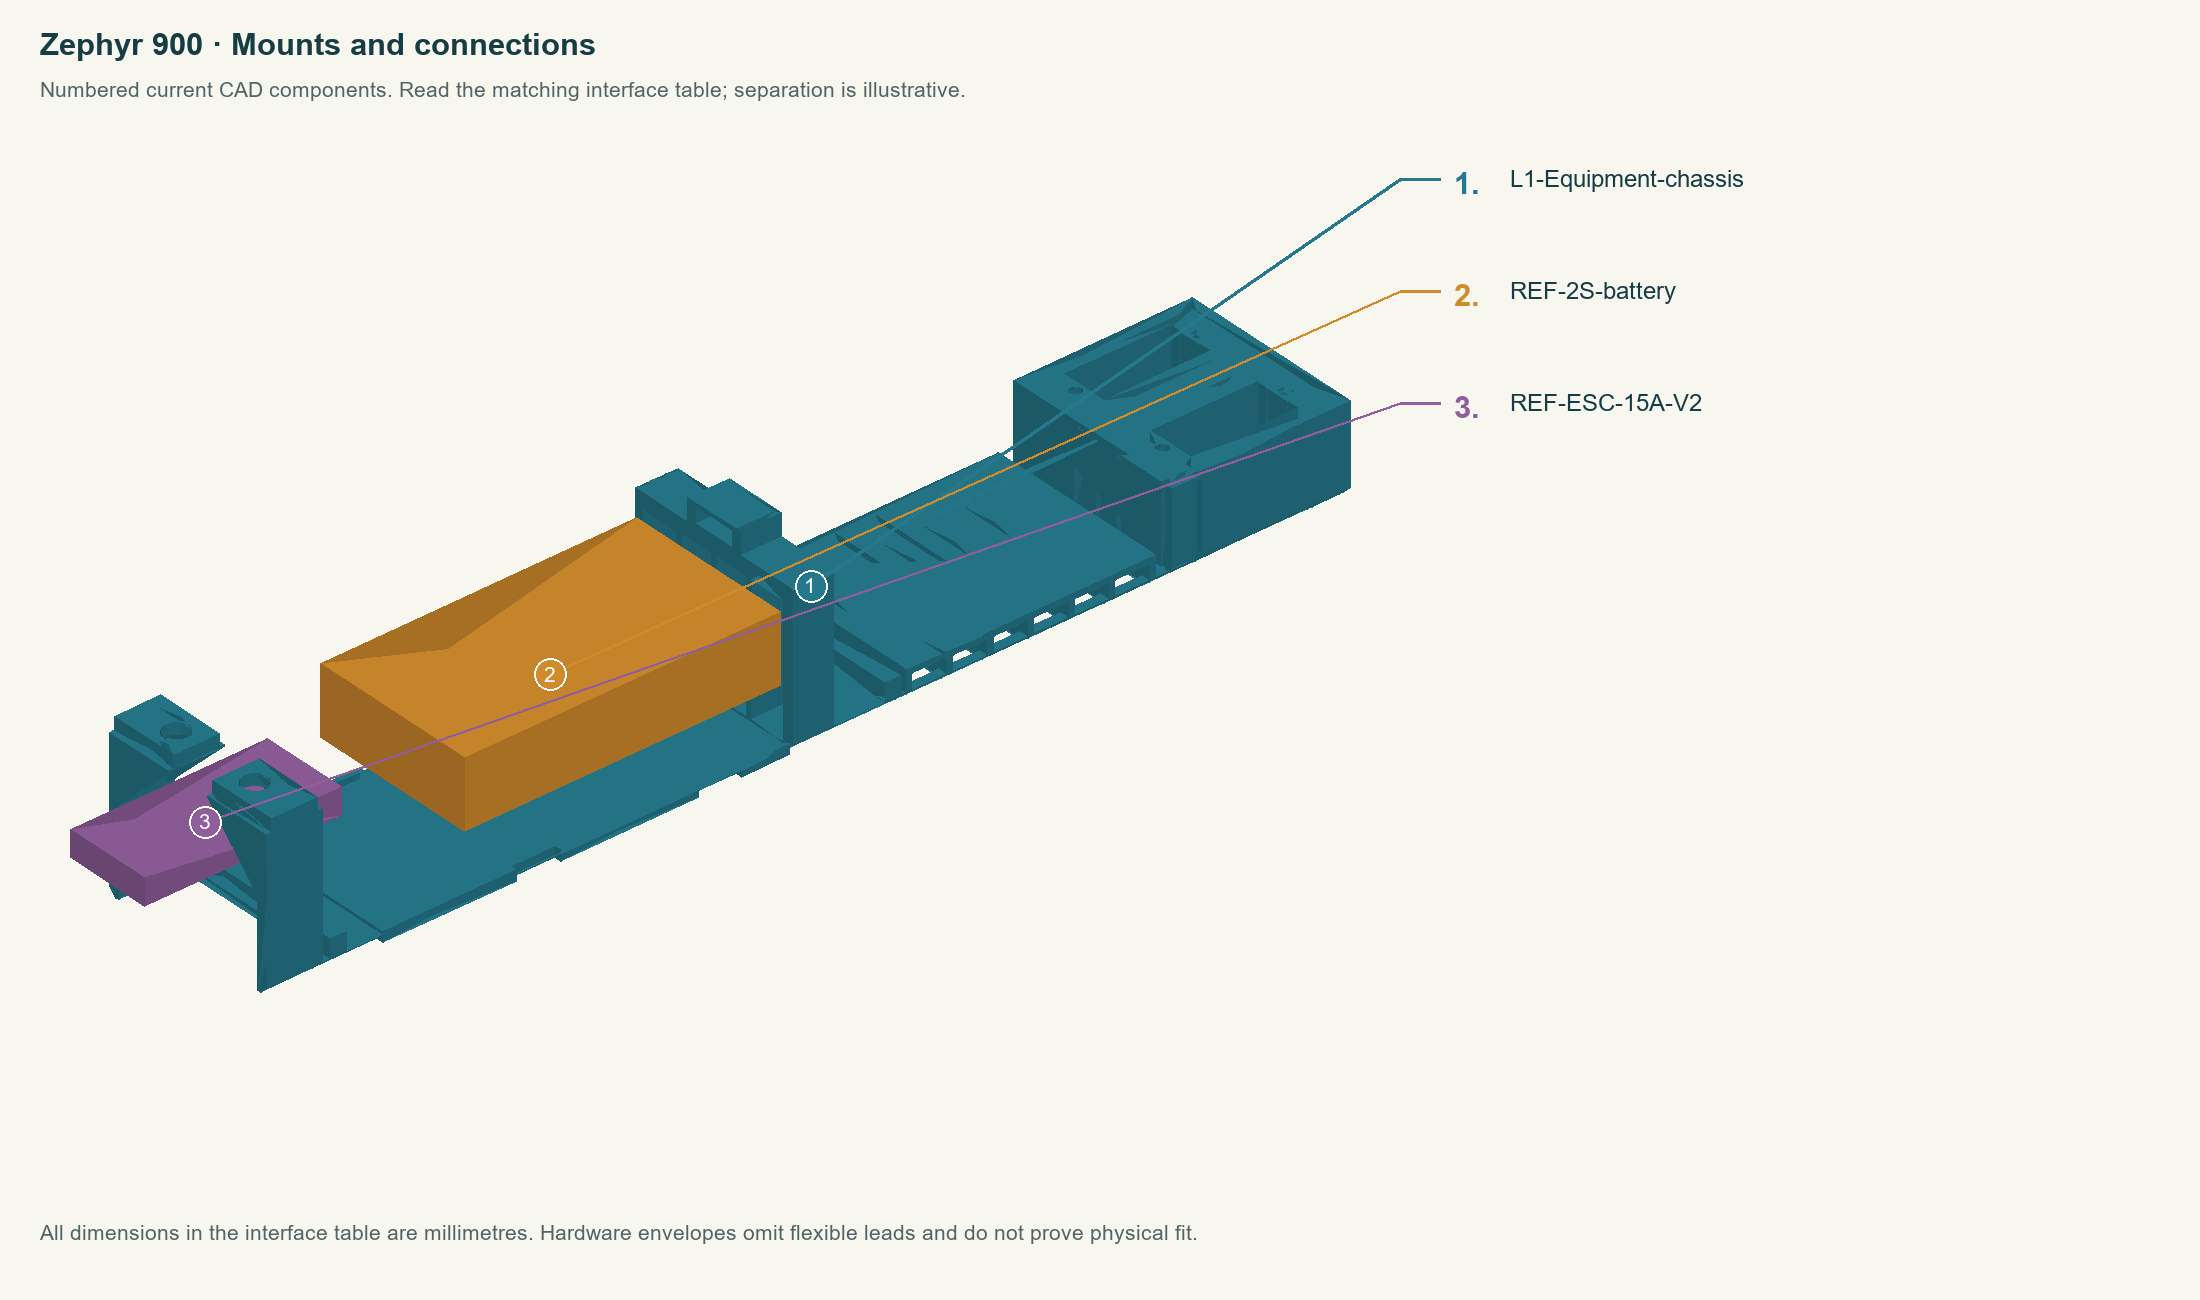
L1-Equipment-chassisREF-2S-batteryREF-ESC-15A-V2
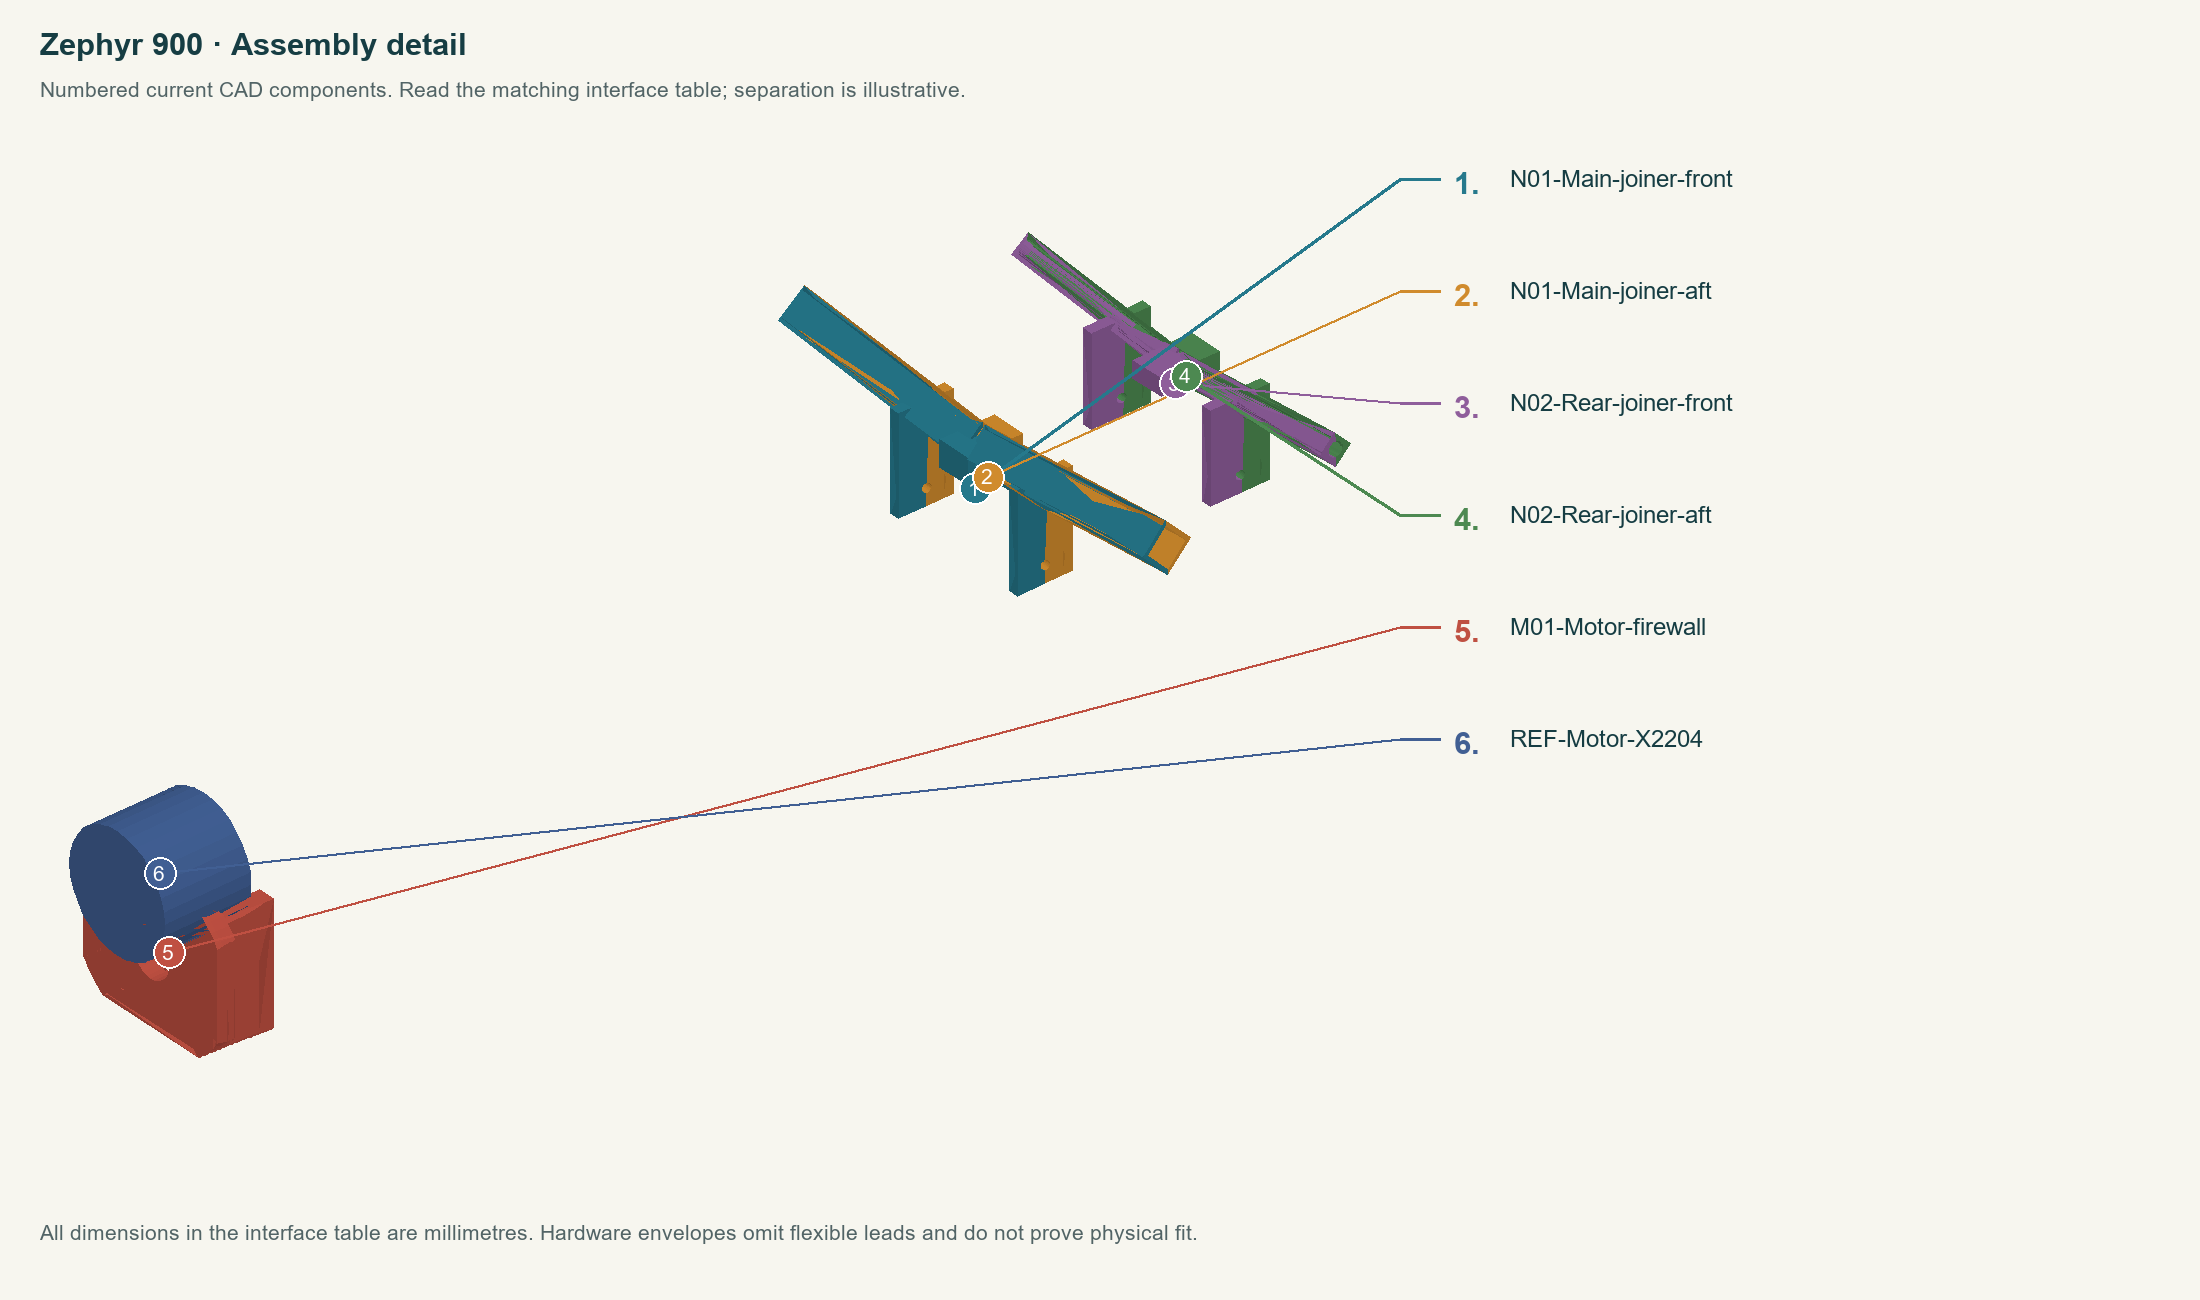
N01-Main-joiner-frontN01-Main-joiner-aftN02-Rear-joiner-frontN02-Rear-joiner-aftM01-Motor-firewallREF-Motor-X2204
Build in this order
- Print and qualify the small pieces
Start with the six L1 coupons on plate 01. Test the intended PLA chassis/servo/horn fits, the retained C20/C40/C60 gauges with actual 6 x 2 mm magnets, Aero skins and ASA motor coupons. Keep the two cap strips from plate 01 for installation.
- Build the magnetic closure before enclosing it
Use four axial 6 x 2 mm discs. Insert the chassis pair from below and bond the body cap strip; install the carrier pair from above and bond its cap strip before bonding the carrier beneath the Aero canopy. Check attracting polarity and keep glue off working faces. Confirm front-up about 5 degrees, 12 mm toward the nose, then lift.
- Dry-fit and bond the equipment chassis
Place the chassis front at X57.6, 23.6 mm behind the side-frame front datum, with chassis floor Z9. Dry-fit both frames, chassis and wing joiners in the open pod; verify wing bolt alignment and canopy seating. Bond specified contact lands only; keep slots/access clear. Retain X275/X303 boom supports.
- Build the carbon-reinforced wing
Keep 5 degrees dihedral per side and 2 degrees incidence. Assemble inner/outer/tip panels over the specified continuous carbon tubes; dry-fit and jig two-part center joiners. Bond tube joints and aligned panel seams; apply specified seam reinforcement, attach tips last, and retain the wing with transverse M2 bolts at X214.5/X261. Fairings bond to center cover only.
- Assemble tail and controls
Slide the three pushrod guides on the 8 mm boom before the tail mount. Align stabilizer to wing and square the fin; retain the stabilizer with two M2 fasteners and preserve the keyed fin sequence. Use only the L1 integral-horn elevator/rudder, tape hinges and 0.8 mm pushrods. Inspect travel for binding.
- Fit hardware before closing access
Transfer the real motor mounting pattern to the coupon, then firewall; verify screw engagement. Fit candidate motor/ESC, purchased prop, two HS-40 servos and AR410 or separately checked receiver. Strap battery independently, check leads/cooling, test equipment in the open chassis, and keep the cowl removable.
- Record actual mass and ground checks
Weigh and balance the completed ground prototype with its actual flight battery; test retention, bond/load behavior and controls. Use the calculated 348.7 g and X211.58 CG only as estimates.
- Use the original 1480 KV motor with a purchased GWS 8 × 4 prop and matching supplied adapter. The 250 gf / 4.1 A 2S manufacturer result is a bench reference, not installed climb performance.
- A 1 mm resilient receiver pad and strap leave the antenna and plugs accessible. Verify the long servo screws do not touch any moving horn or canopy surface.
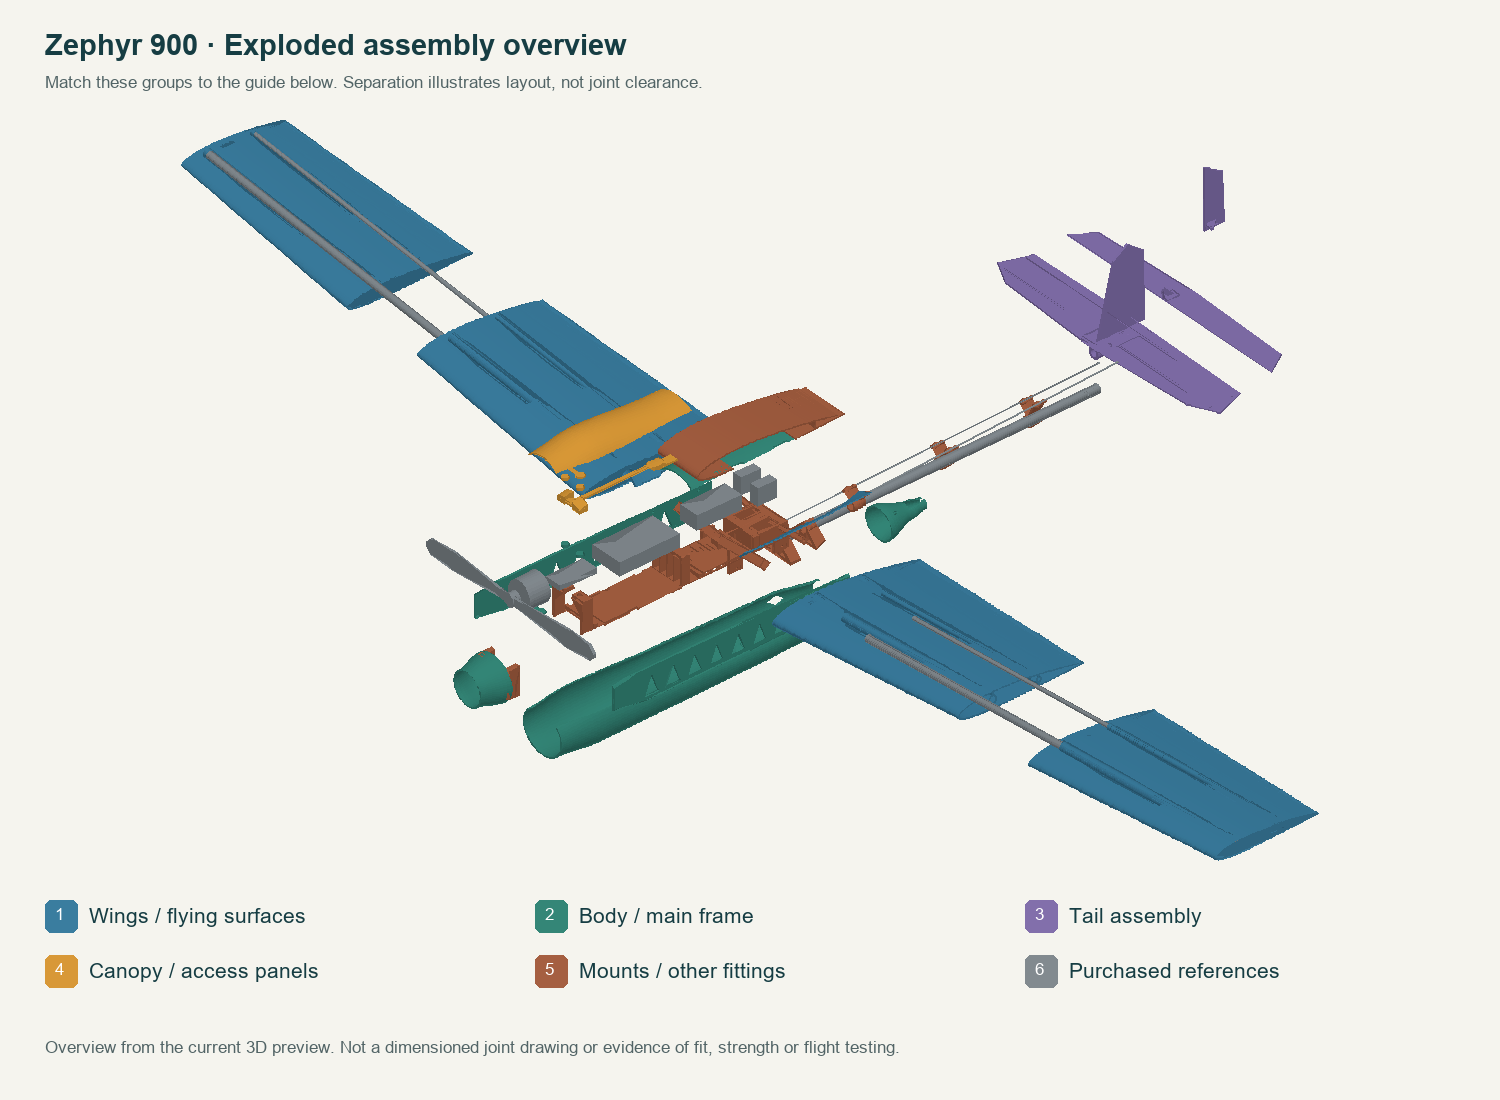
Power and radio setup
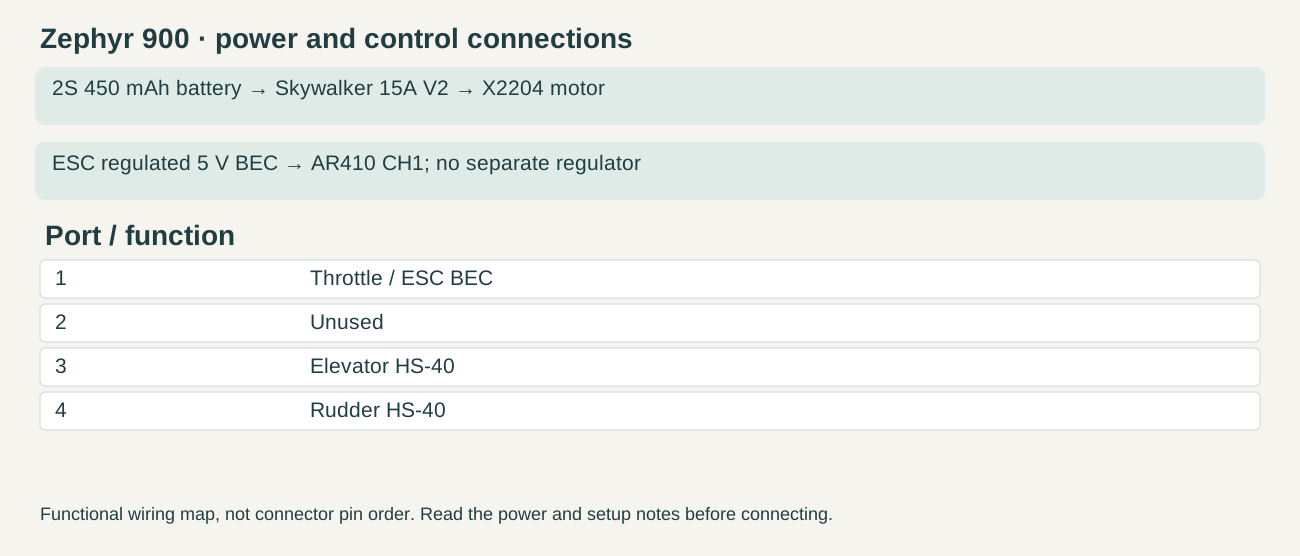
- Use an analog-compatible 22 ms setup. Verify throttle cut and receiver-loss motor stop with the propeller removed.
Keep propellers removed (and Rotor motors disconnected) during setup. Check polarity and regulated bus voltage before plugging in the receiver/servos. Center servos before fitting horns; check neutral, direction and free travel before connecting rods. Configure throttle cut and receiver-loss response, then test them on the installed system.
Fit and bond method
- Dry-fit and mark orientation, contact lands and insertion depth before mixing adhesive. Record actual tube, printed socket and coupon dimensions.
- Use an adhesive whose maker supports both actual materials. Prepare only the intended bond lands as directed; remove dust and let surfaces dry. Do not solvent-wipe a filament without checking compatibility.
- Make matching sacrificial coupons with the same filament, orientation, carbon/wood if applicable, preparation and adhesive. Cure for the maker’s complete schedule and test the joint before committing to inaccessible or structural bonds.
- Bond on an alignment jig. Keep hinges, captive nuts, moving shafts, servo cases, leads and access covers free. Retain evidence of cure, bondline fit and test behavior; no adhesive process or load rating is established by these files alone.
Fasteners and linkage lengths
A listed starting screw length is not permission to bottom a screw in a motor or crush a servo ear. Measure the mount, washer and nut stack; verify locking-thread engagement and moving-part clearance. For a blind threaded motor hole, compare protrusion below the mounting face with the manufacturer’s maximum permitted penetration.
Set servos to neutral and surfaces straight. Install the chosen retained ends with their required thread engagement, measure the ball/pin-center distance, then mark the rod between those actual ends. Viewer centerline lengths are not bare rod cut lengths. Check both travel limits and combined gear/door states before final locking.
What still prevents a completed flying release
- Actual motor-ear transfer, wire/horn/canopy clearance, printed joint strength and measured mass/CG/flight behavior.
Use the measurement record to report actual fits and test results. A geometric pass is not a structural rating, slicer validation or flight test.
Detailed source guide
Included in ZIP: Retained model-specific source instructions. Current R2 interface and replacement instructions above take precedence where a retained source describes an earlier revision.